Ground Systems[UGV-LOGISTICS]
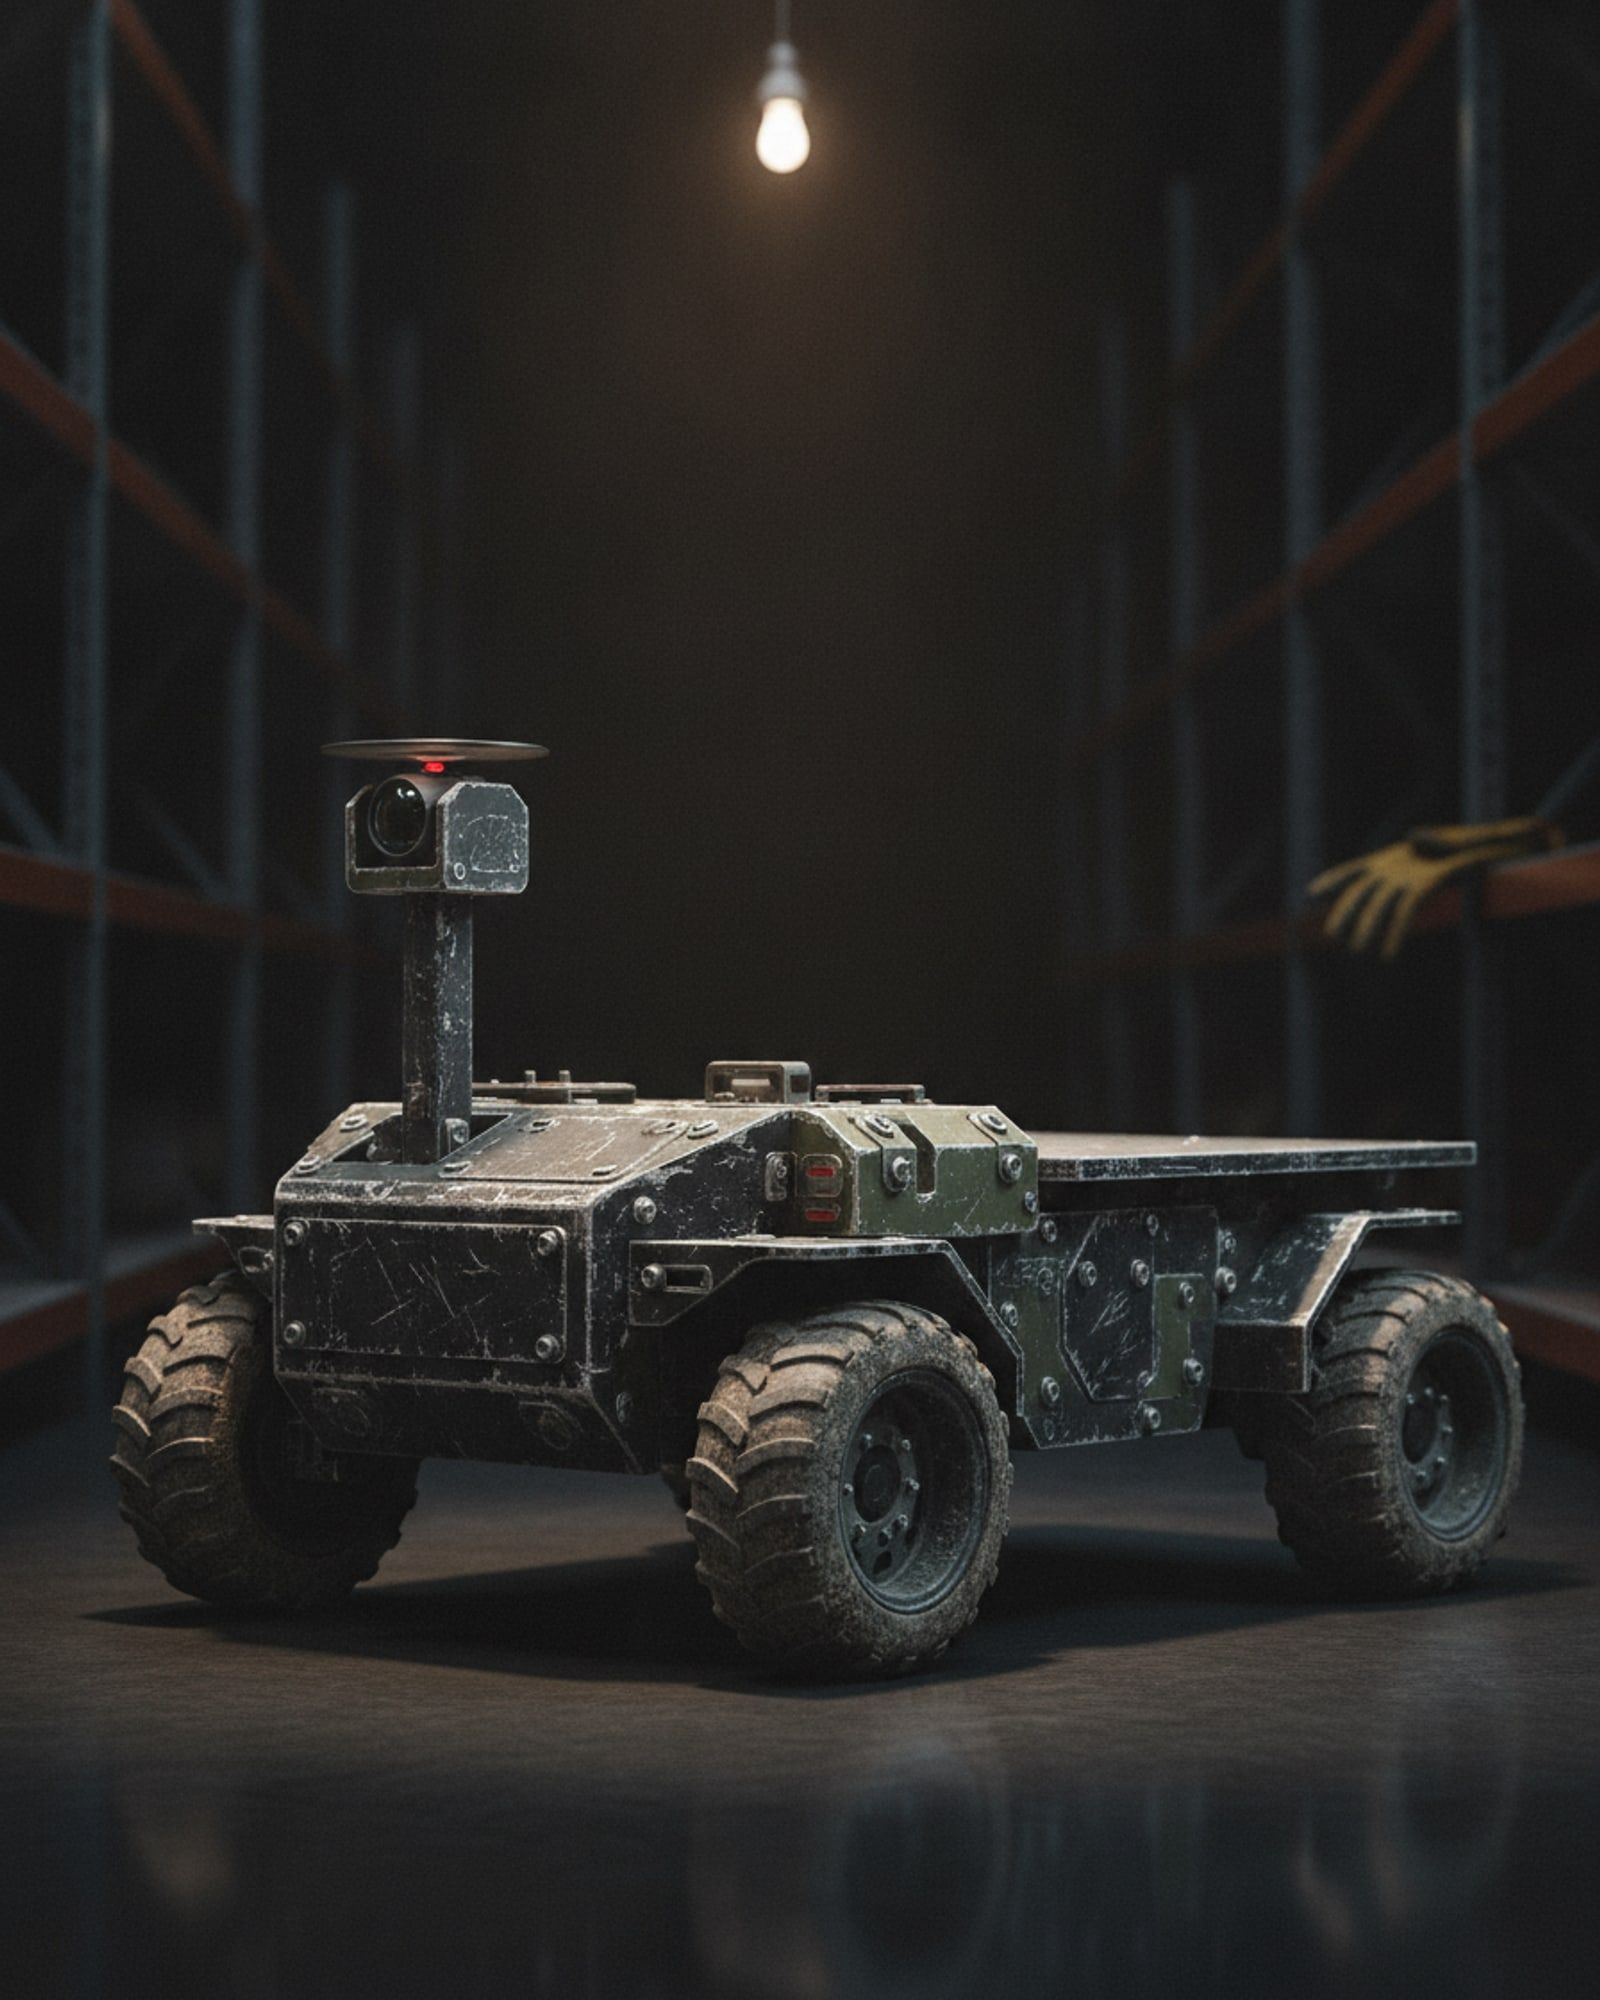
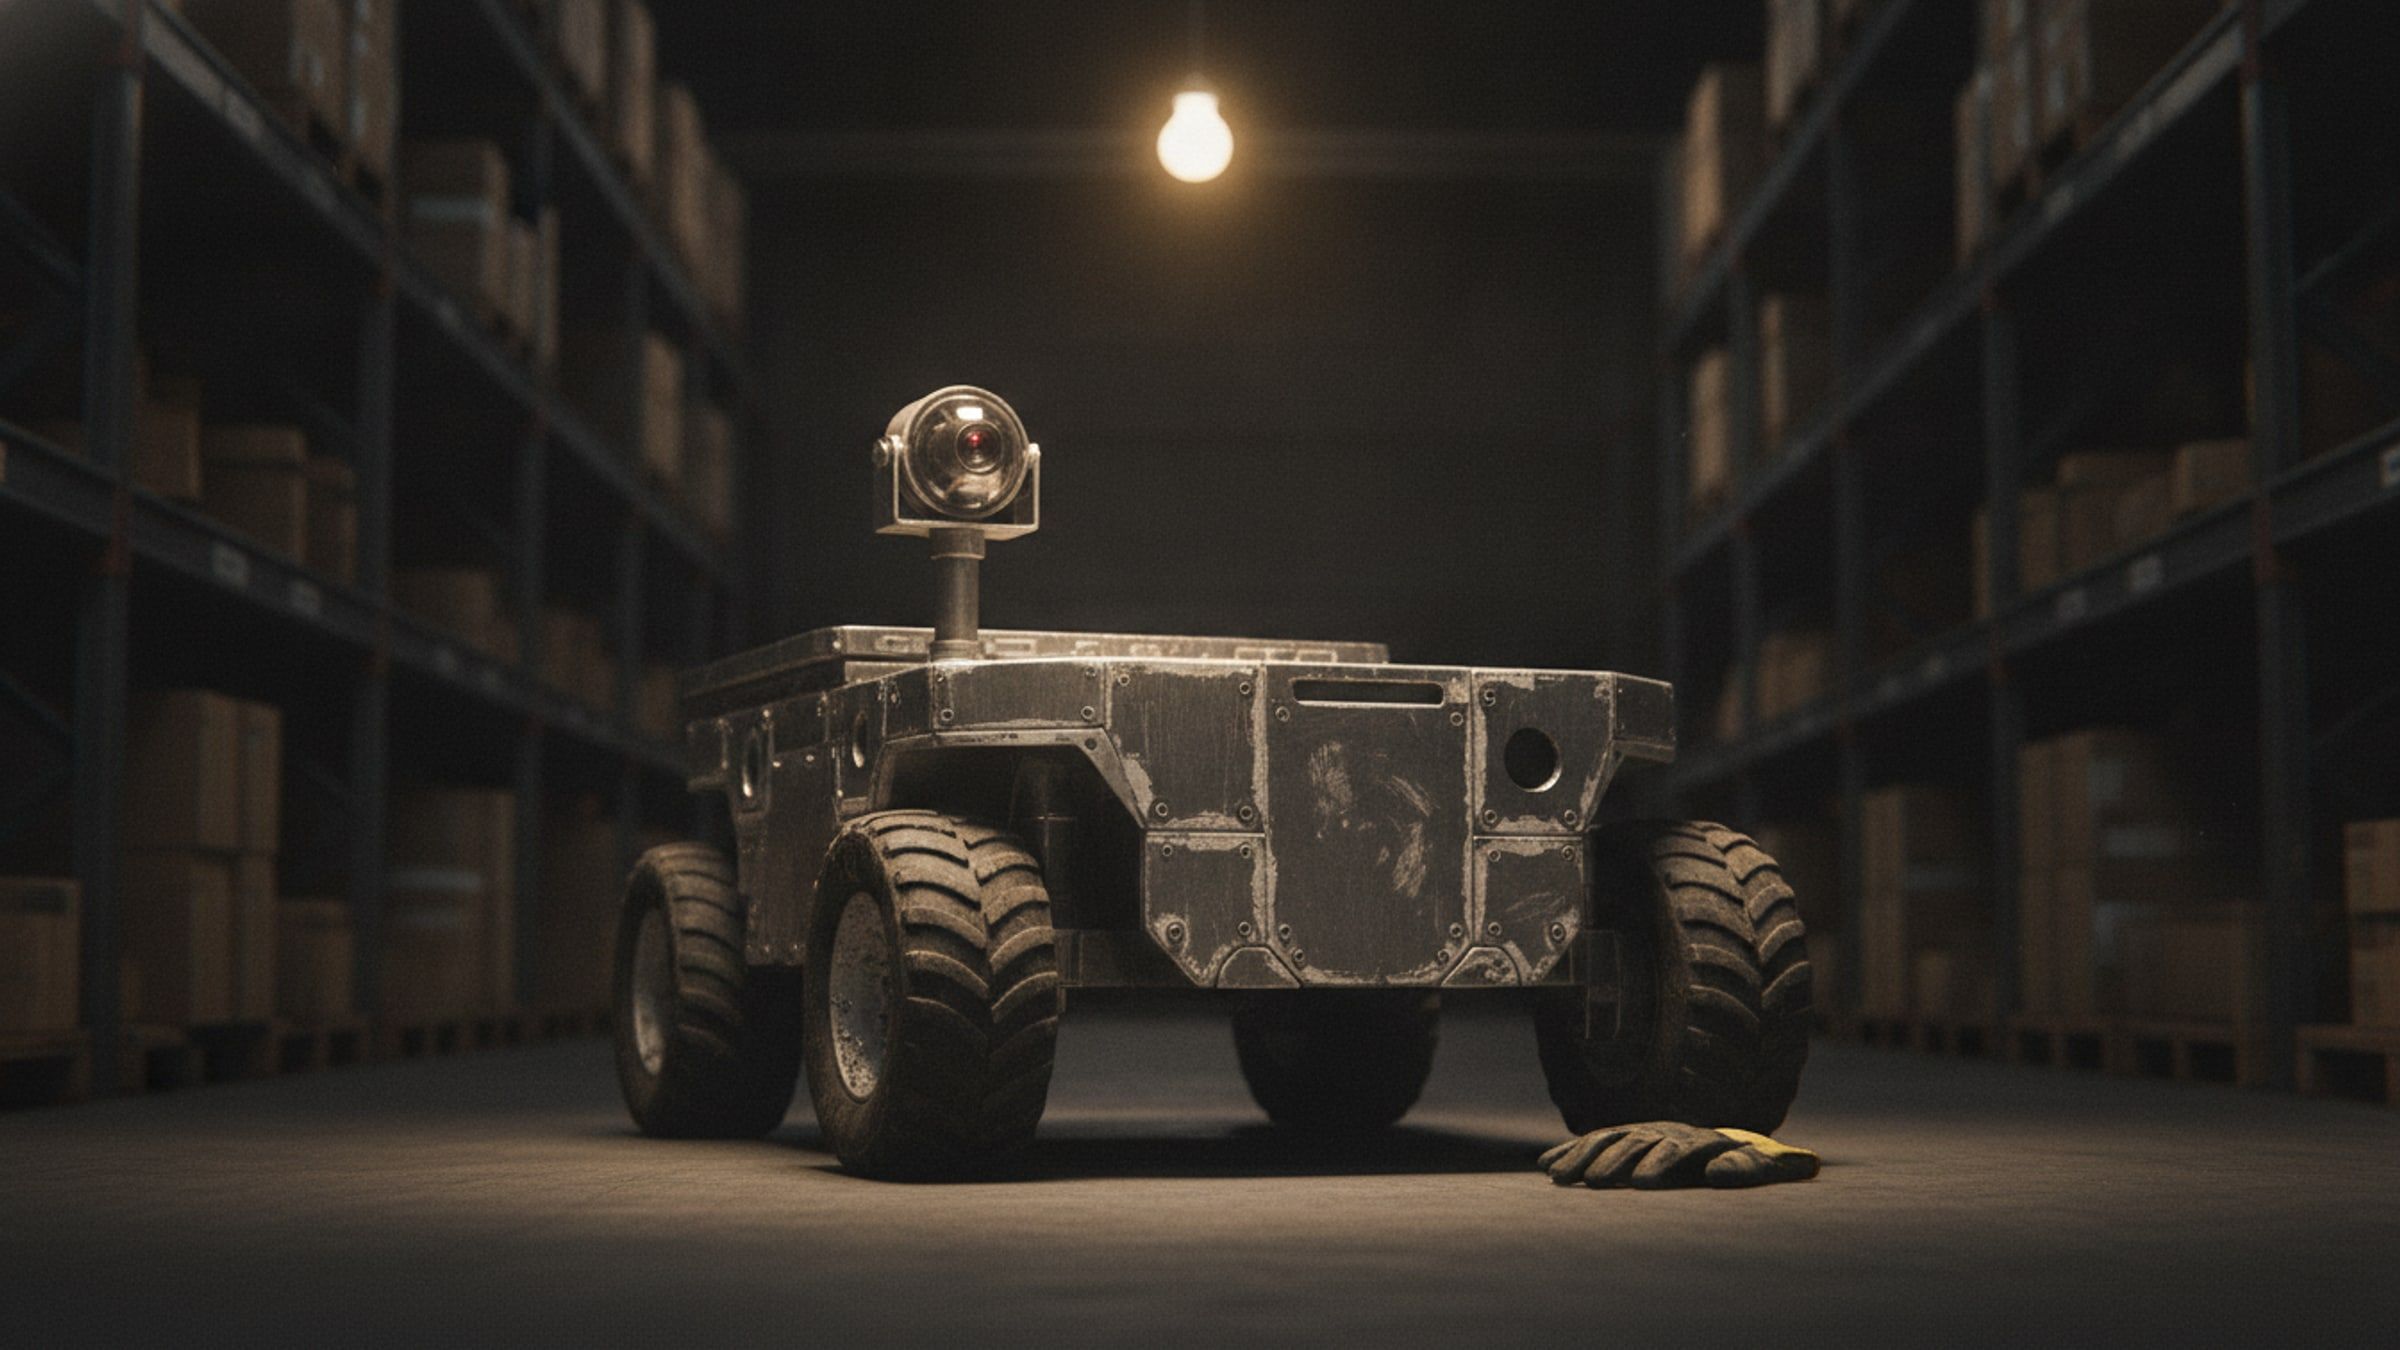
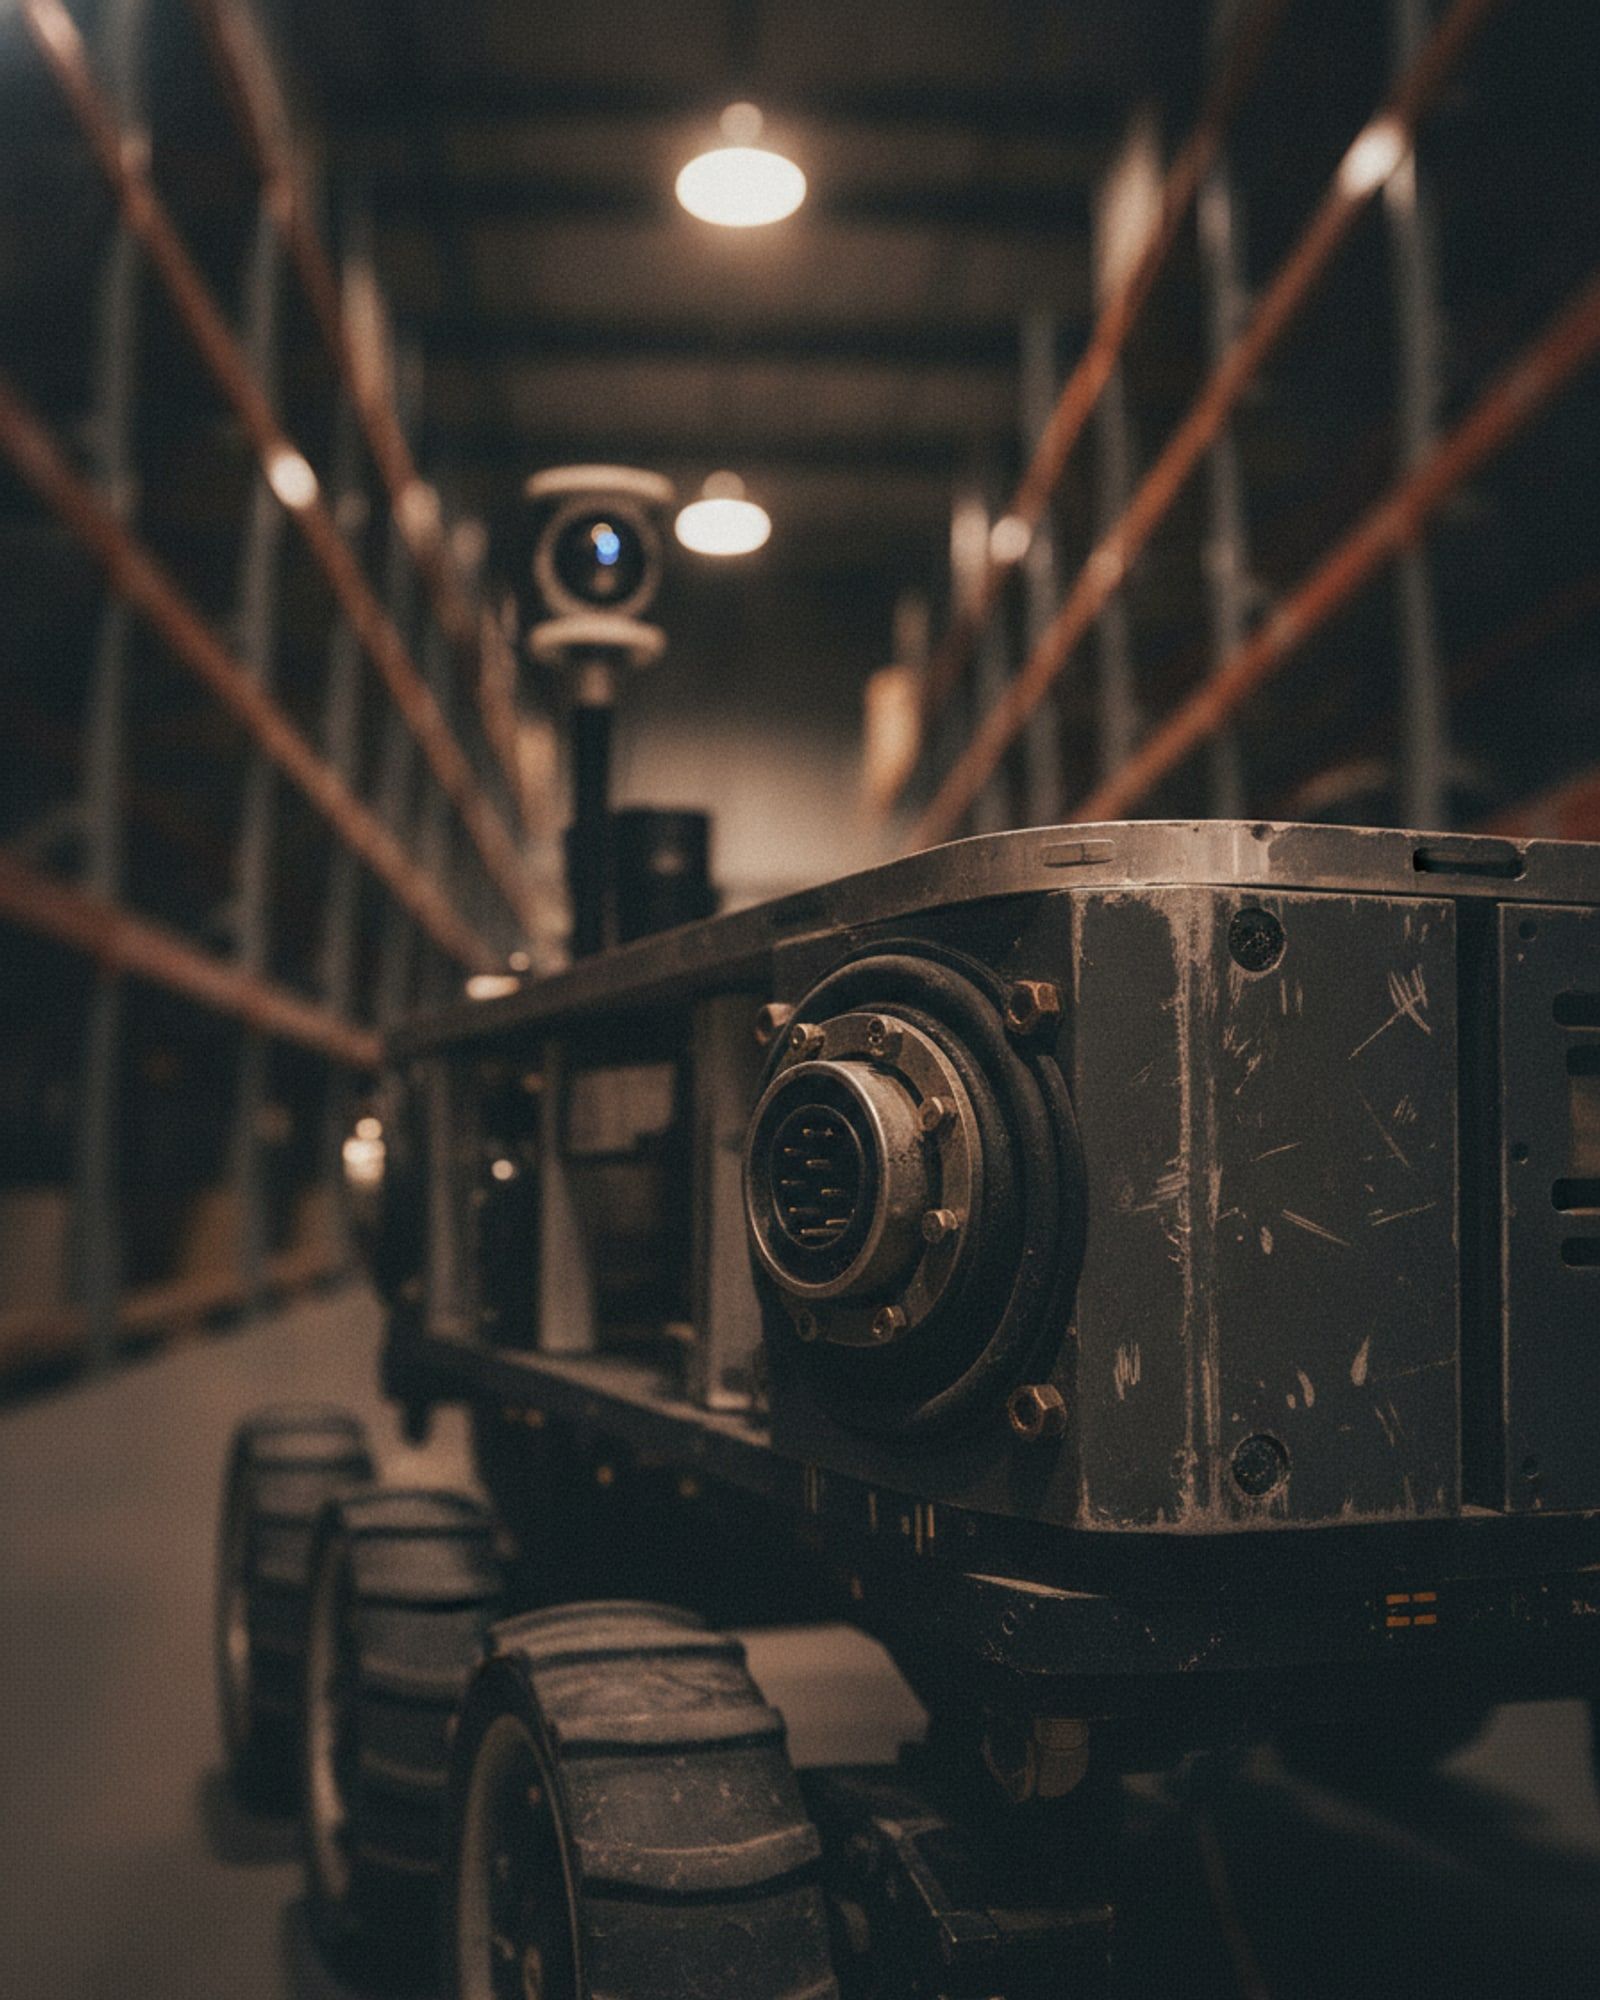
A skid-steer rover that maps a depot or warehouse once, then carries loads between named points on its own.
- Footprint
- 1.2 x 0.84m
- Drive
- Four-wheel skid steer
- Navigation
- Laser map, no satellite
- Payload
- On request
Overview
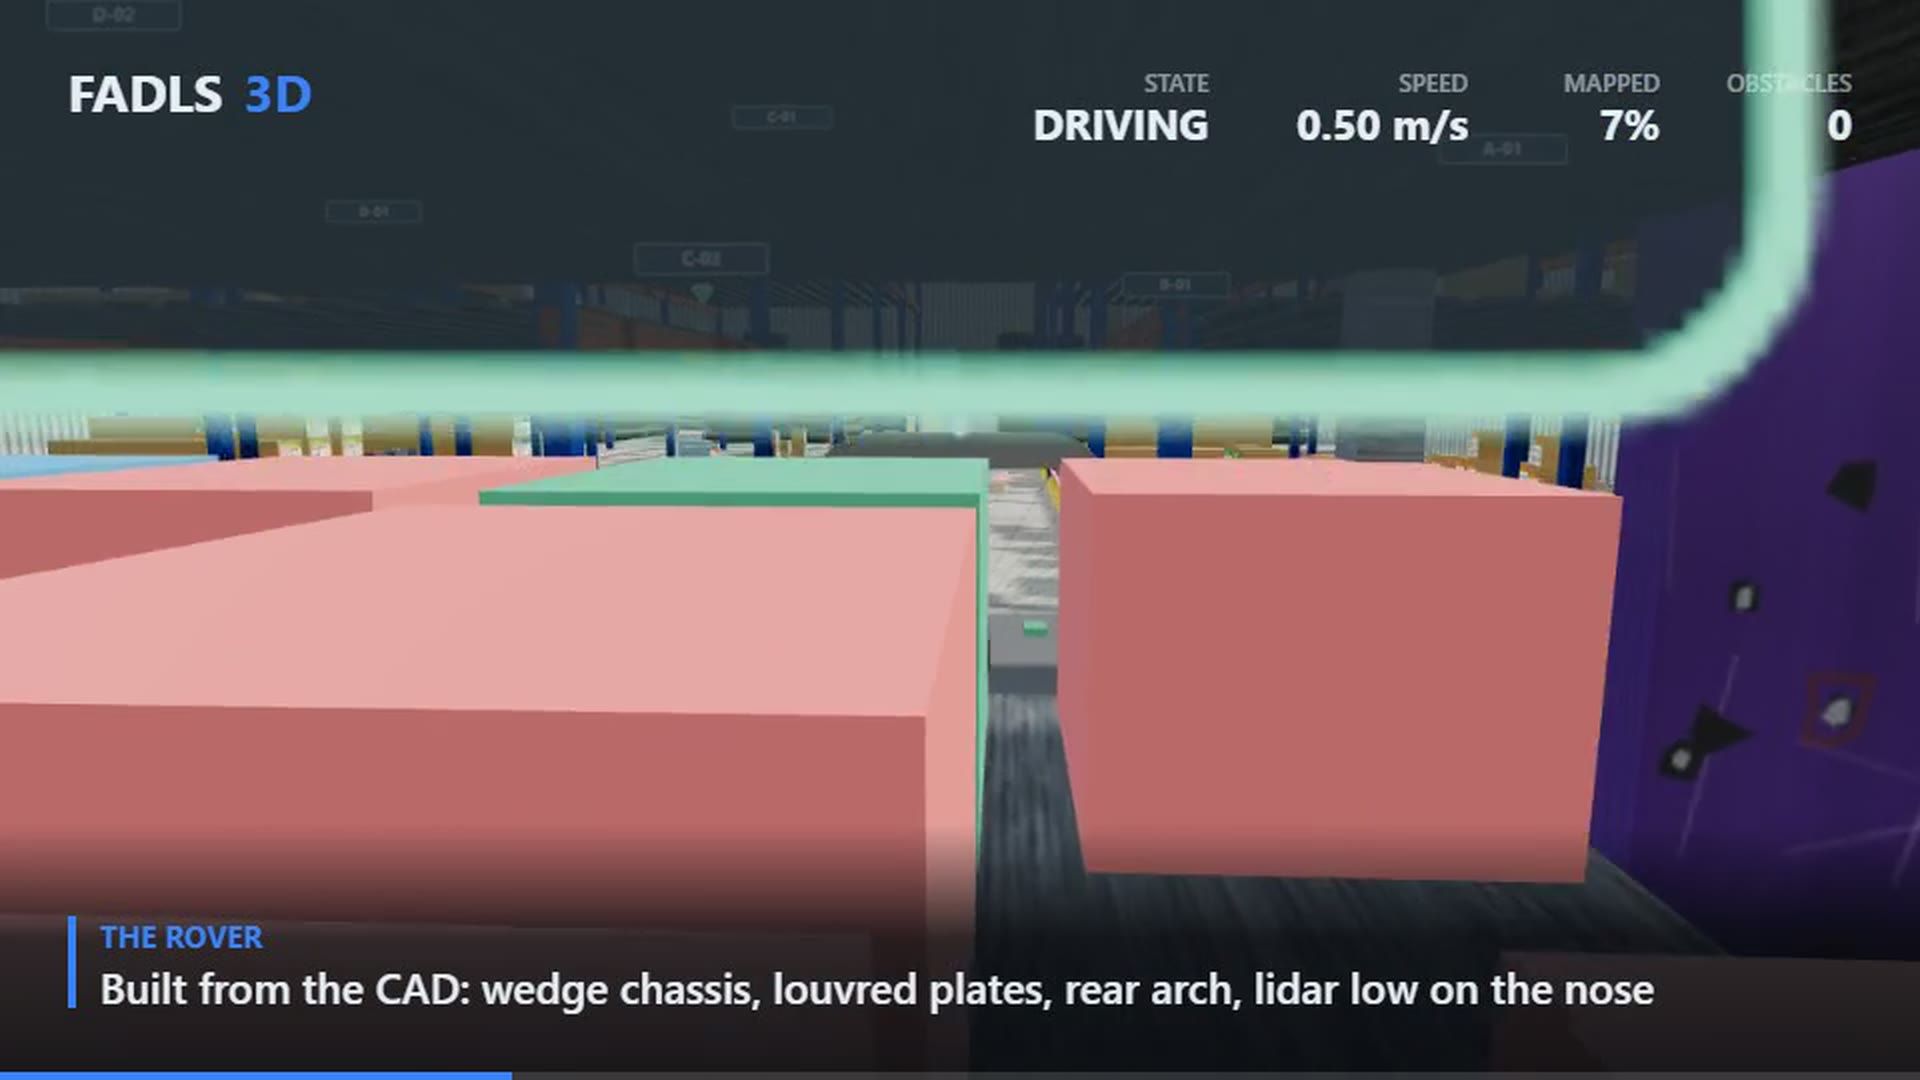
Moving stores inside a depot is repetitive, and the vehicles that do it are driven by people who are needed elsewhere. This rover is driven around the building once to build a map, after which a destination is a name rather than a route.
A laser scanner and an inertial solution keep it located on that map with no satellite signal indoors. Areas it must never enter are painted onto a keep-out layer. Tight passages it cannot plan through are crossed by a dedicated alignment routine that checks it is centred and square before committing, and backs out and retries rather than scraping through.
System qualities
01 / 06
Mapped once, used for years
Drive it round the floor on a transmitter, save the map, and every later task refers to that map. Re-mapping is only needed when the building changes.
02 / 06
Destinations have names
Record a point by driving to it and naming it. Afterwards the rover is sent to a name, and reports back when it arrives or when it cannot.
03 / 06
Keep-out areas it will not enter
Stairs, offices, open floor and loading doors are painted onto a keep-out layer. The planner treats them as solid.
04 / 06
Crosses gaps it cannot plan through
A passage only a few centimetres wider than the rover is crossed by a dedicated routine that lines up on the opening, verifies it is centred and square, and retries or reports failure rather than jamming.
05 / 06
Any screen is the console
One page served by the rover itself opens on a mounted touchscreen, on a controller's browser, or on any phone on the same network. No app to install.
06 / 06
Manual takeover at a touch
Moving a stick on the transmitter takes control back instantly, which doubles as the emergency behaviour.
Specifications
Figures marked undisclosed or on request are released against a stated requirement.
Vehicle
- Footprint
- 1.2 m x 0.84 m
- Drive
- Four-wheel skid steer, planetary gear motors
- Payload
- On request
- Endurance
- On request
- Emergency stop
- Contactor; control electronics stay powered
- Ground clearance
- On request
- Climbing gradient
- On request
- Turning radius
- Skid steer; turns within its own length
- Ingress protection
- On request
- Charge time
- On request
Navigation
- Mapping
- Laser scanning with loop closure
- Localisation
- Laser map fused with inertial measurement
- Satellite navigation
- Not required
- Keep-out zones
- Painted mask layer
- Narrow passages
- Dedicated alignment and crossing routine
Control
- Console
- Browser page served by the vehicle
- Manual override
- Transmitter, instant
- Teleoperation fallback
- Direct transmitter control at any moment
Documentation
- Ground Systems overviewAvailable on request
Applications
Works with
These are built to operate together, on one network and one picture.
The floor drives itself.