Autonomy and AI[AI-TRACK]
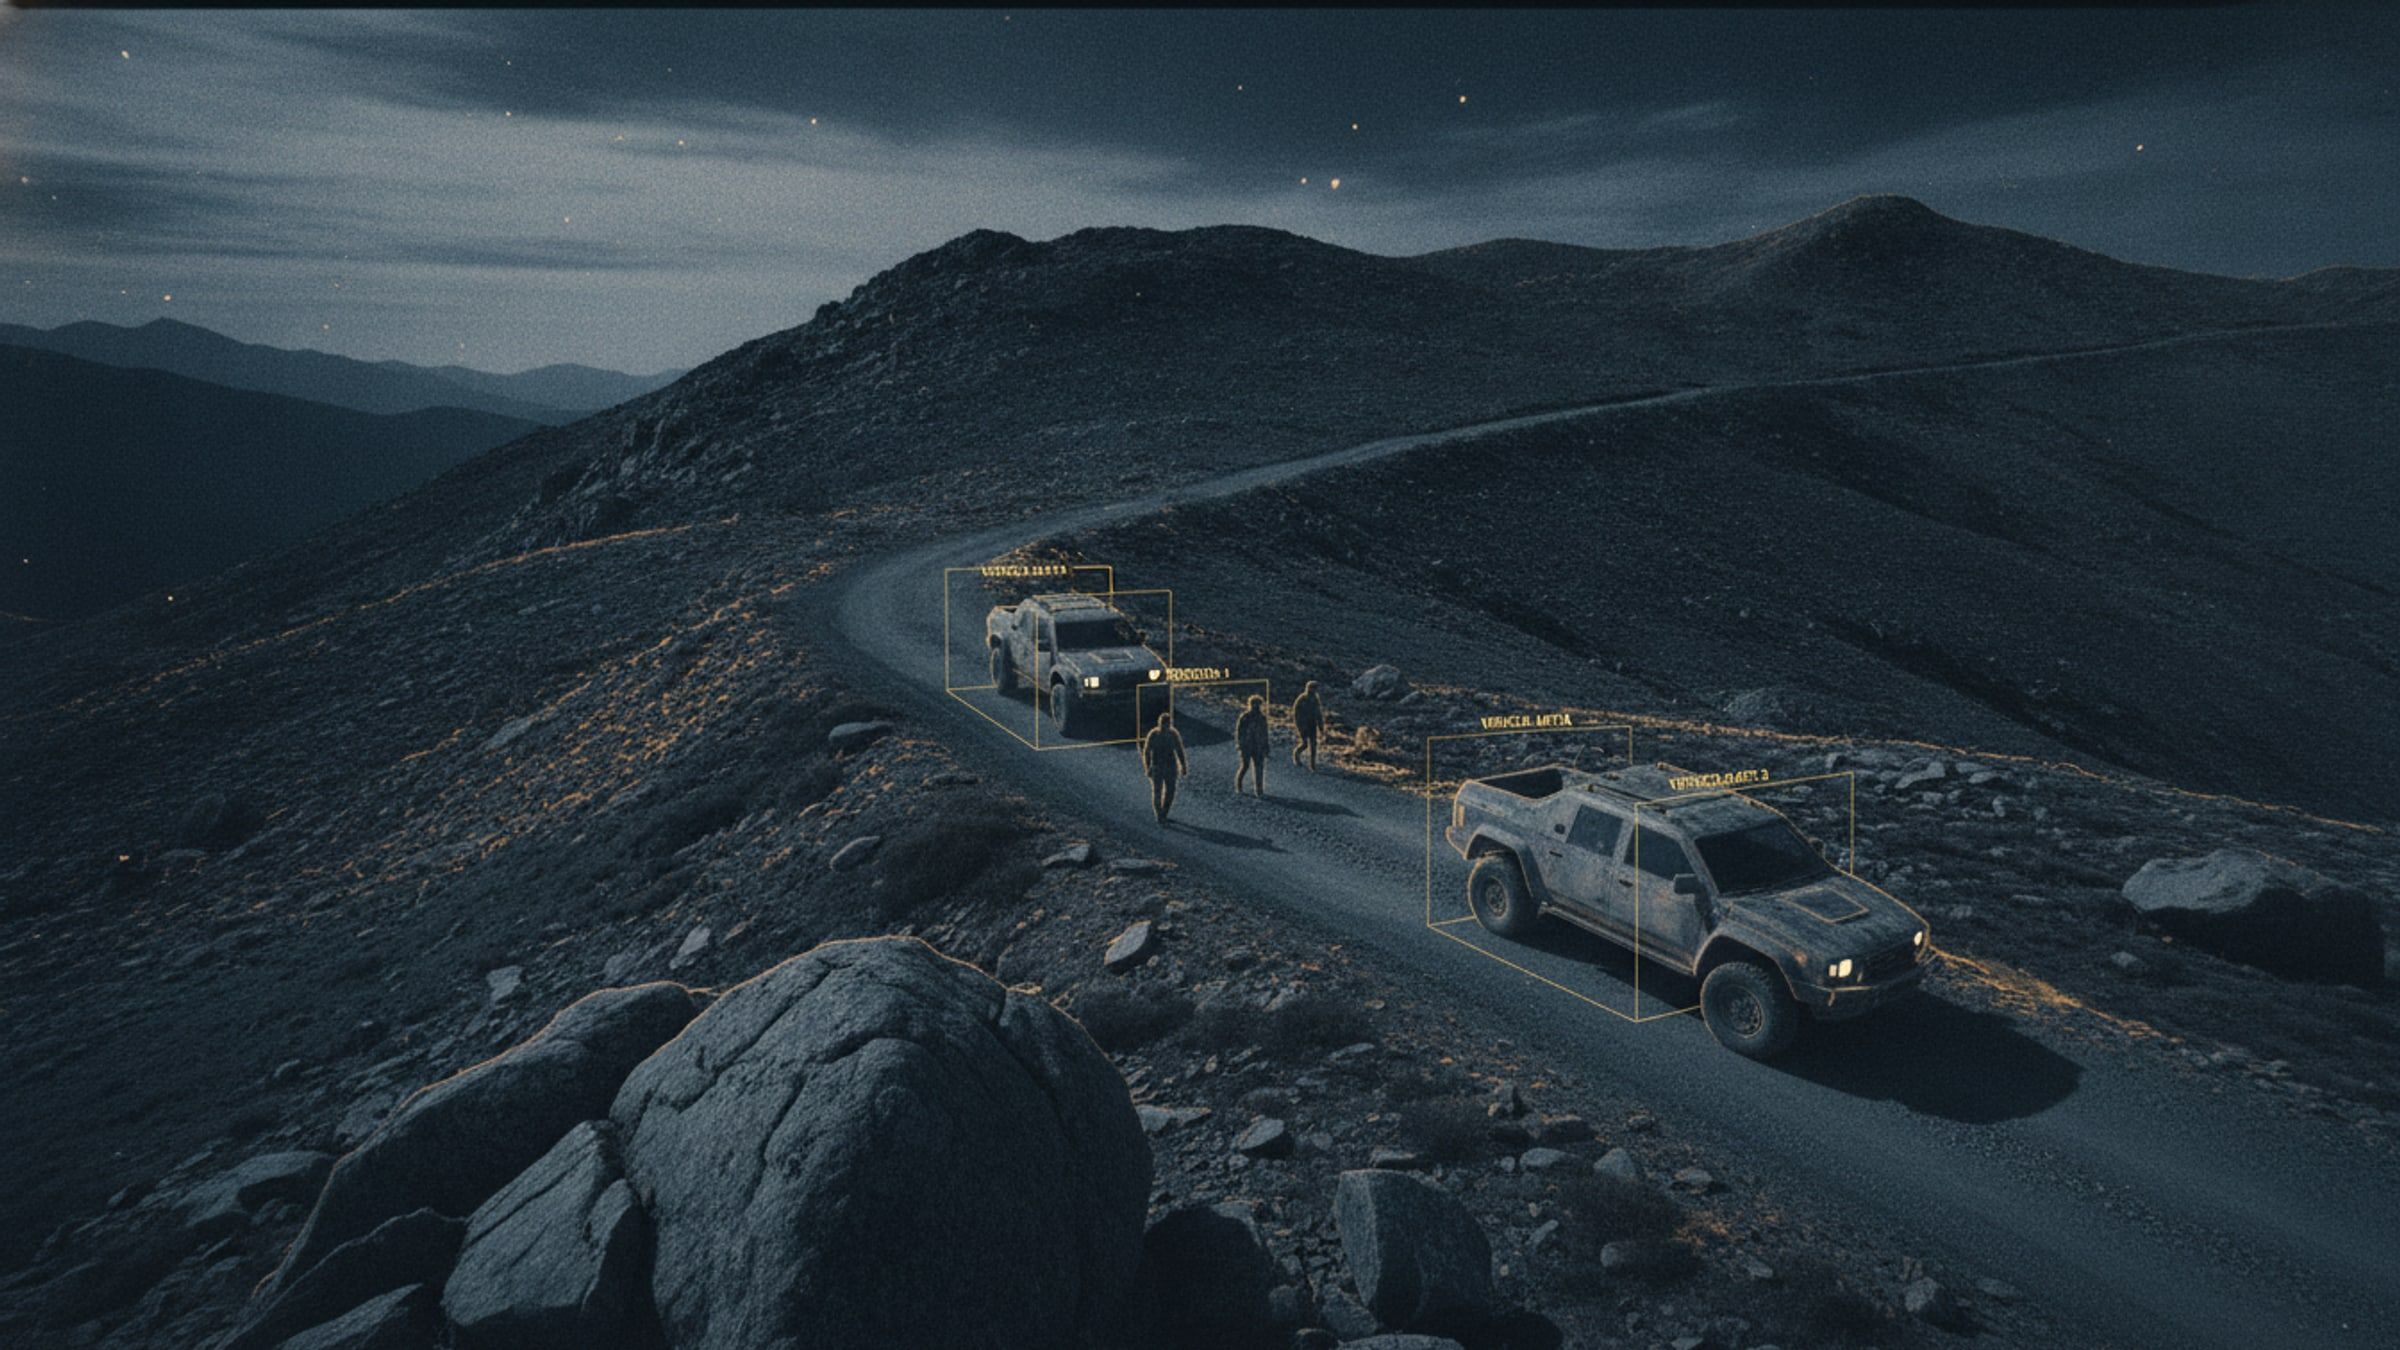
Detection and tracking of people and vehicles in live video, running on the aircraft rather than in a data centre.
- Runs on
- Aircraft or field processor
- Classes
- People and vehicles
- Connectivity
- None required
- Frame rate
- On request
Overview
An operator watching a live feed for hours will miss things; that is a property of people, not of training. Detection that runs continuously does not get tired, and its job is to raise what is worth a human look.
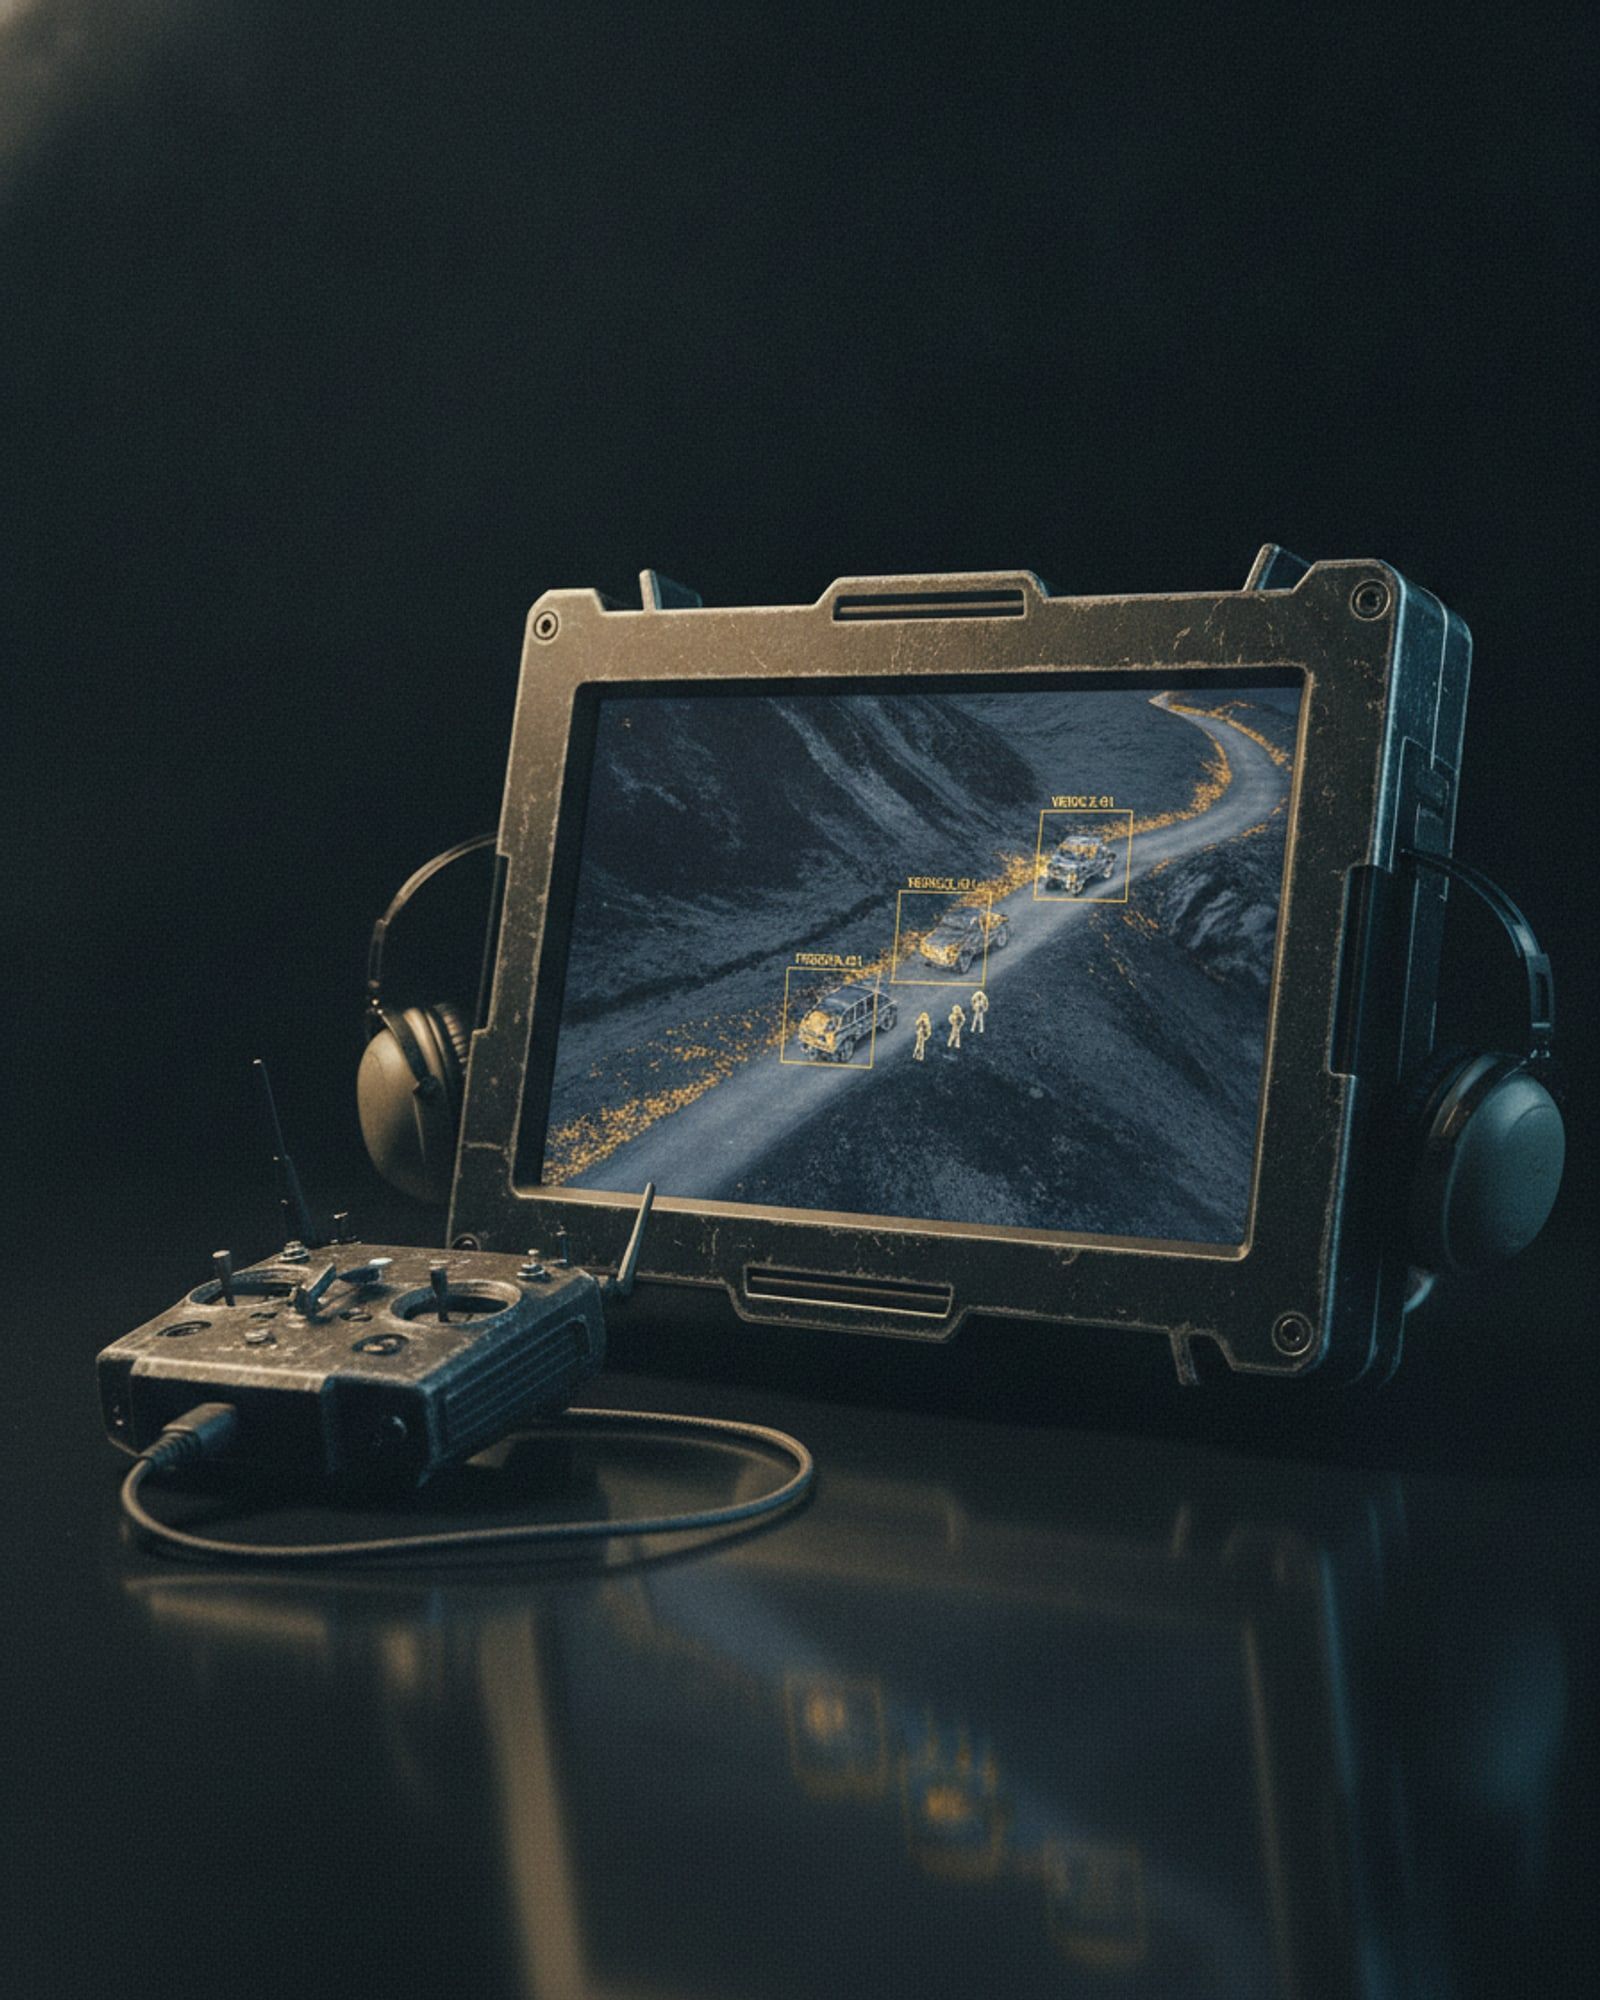
The model runs on the aircraft or on a small processor beside the operator, so nothing depends on a link back to a server. Detections carry a class, a confidence and a track identity that persists as the subject moves, and can drive the sensor to keep a subject centred.
System qualities
01 / 04
On the aircraft, not in a cloud
Inference happens where the camera is. There is no upload, no latency penalty and no dependence on a link that may not exist.
02 / 04
Tracks, not just detects
A subject keeps its identity across frames, through partial occlusion, so a count is a count rather than a repeated detection.
03 / 04
Drives the sensor
A selected track can command the gimbal, keeping the subject centred while the aircraft flies its own task.
04 / 04
Raises, does not decide
Output is a flagged detection for a person to judge. The system does not take an action on its own.
Specifications
Figures marked undisclosed or on request are released against a stated requirement.
Deployment
- Location
- Airborne processor or field workstation
- Connectivity
- Not required
- Processor
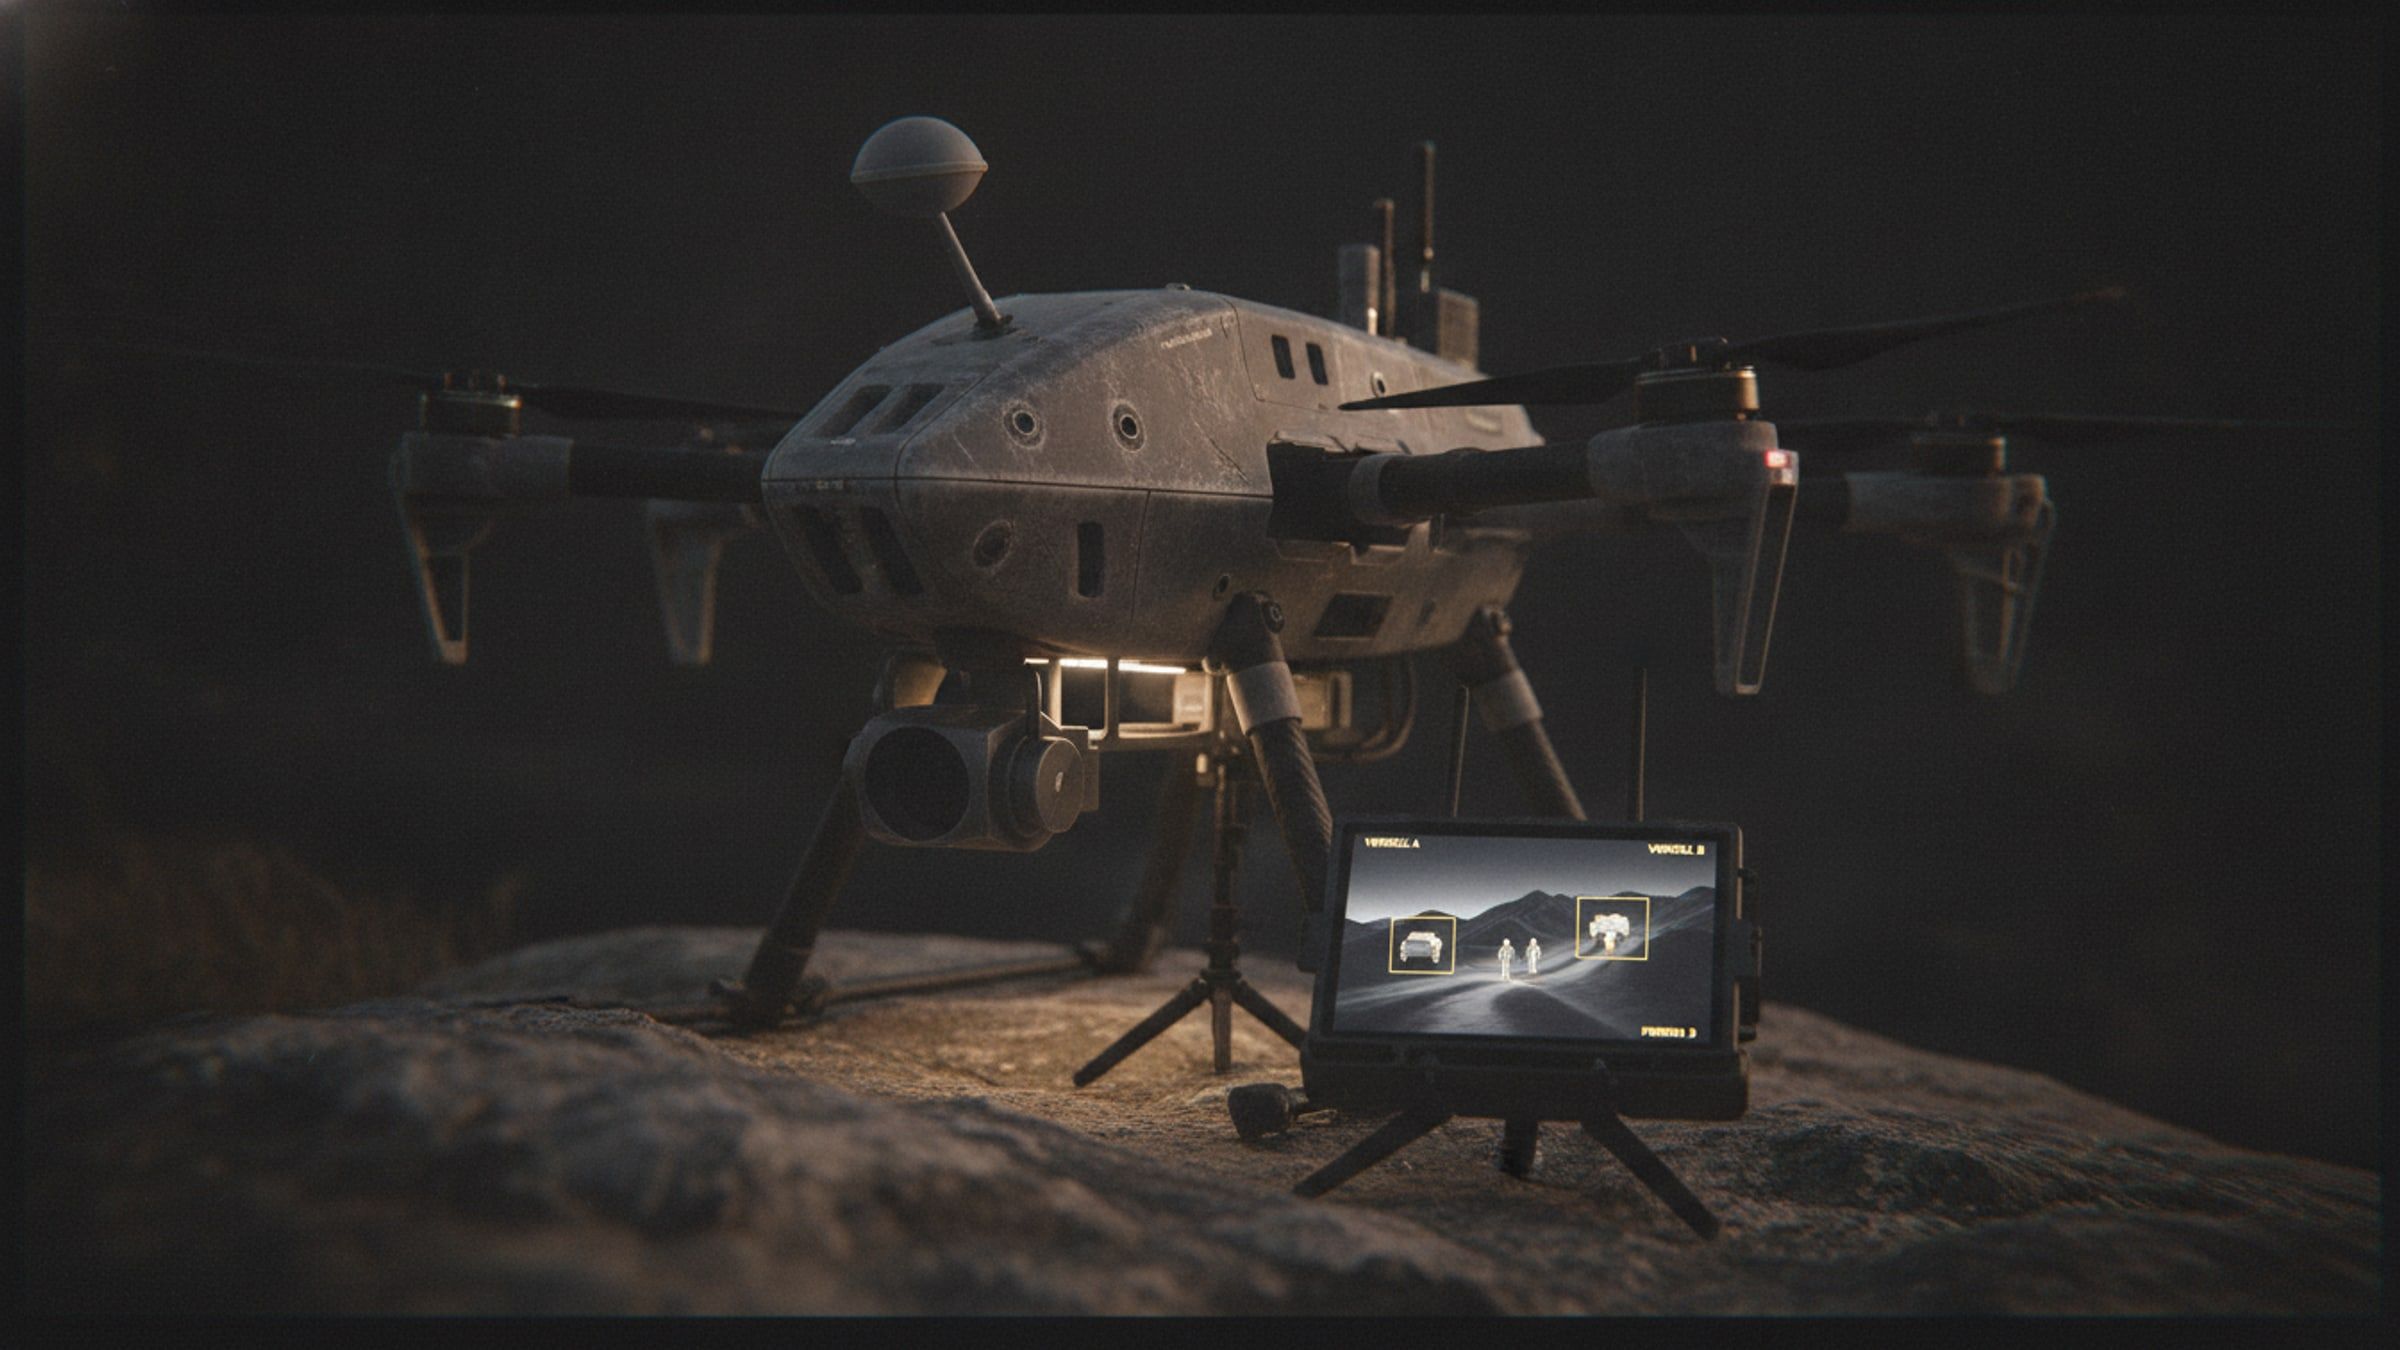
- Runs on the aircraft or on a field workstation
Detection
- Classes
- People, vehicles; extensible on request
- Frame rate
- On request
- Sensors
- Day and thermal video
- Latency
- On request
- Minimum target size
- On request
Tracking
- Identity
- Persistent across frames and occlusion
- Sensor control
- Selected track drives the gimbal
- Simultaneous tracks
- On request
Output
- Interfaces
- Overlay video, structured detections to the control station
Documentation
- Autonomy and AI overviewAvailable on request
Works with
These are built to operate together, on one network and one picture.
Find, follow, flag.